SeeSehen
Weeks 1–3Wochen 1–3Photo Booth BotFotobox-Bot
Pi 5 + camera setup, an image as an array of numbers, LEDs and a button.Pi-5- & Kamera-Einrichtung, ein Bild als Zahlen-Array, LEDs und ein Taster.
Colour HunterFarbjäger
OpenCV filters, HSV masks, contours, and real per-frame latency budgets.OpenCV-Filter, HSV-Masken, Konturen und echte Latenzbudgets pro Bild.
Break the RulesRegeln brechen
Motion detection, a lighting stress test, and agreeing the class privacy rules.Bewegungserkennung, ein Beleuchtungs-Stresstest und die gemeinsamen Datenschutzregeln.
LearnLernen
Weeks 4–6Wochen 4–6Data CollectorDatensammler
Dataset capture, a bias/blur/duplicate report, train/validation/test splits.Datensatz-Erfassung, ein Bias-/Unschärfe-/Duplikat-Report, Train/Val/Test-Aufteilung.
First BrainErstes Gehirn
Teachable Machine to TFLite, on-device thresholds and smoothing.Teachable Machine zu TFLite, Schwellenwerte und Glättung auf dem Gerät.
Train Your Own AIEigene KI trainieren
Transfer learning on the Pi itself, a confusion matrix, a model card.Transfer Learning direkt auf dem Pi, eine Konfusionsmatrix, eine Modellkarte.
DetectErkennen
Weeks 7–9Wochen 7–9Speed LabTempo-Labor
Latency vs throughput, INT8 quantisation, threaded pipelines, thermals.Latenz vs. Durchsatz, INT8-Quantisierung, Thread-Pipelines, Temperaturmessung.
Object SpotterObjekt-Spotter
YOLO26n real-time object detection, IoU/NMS, centroid tracking.YOLO26n-Objekterkennung in Echtzeit, IoU/NMS, Schwerpunkt-Tracking.
Teach YOLO New TricksYOLO Neues beibringen
Image annotation, a custom YOLO dataset, fine-tuning on the Pi.Bildannotation, ein eigener YOLO-Datensatz, Fine-Tuning auf dem Pi.
Deploy — The CapstoneEinsetzen — Der Abschluss
Weeks 10–12Wochen 10–12A headless edge-AI system, evaluated against its own specEin bildschirmloses Edge-AI-System, ausgewertet gegen die eigene Spezifikation
Pairs choose a capstone in Week 4 and build toward it from Week 7 — a real camera, a trained or fine-tuned model, and a physical action, running without a screen. They choose from six original briefs:Zweierteams wählen in Woche 4 ein Abschlussprojekt und arbeiten ab Woche 7 darauf hin — eine echte Kamera, ein trainiertes oder feinabgestimmtes Modell und eine physische Aktion, ganz ohne Bildschirm. Sie wählen aus sechs eigenen Aufgabenstellungen:
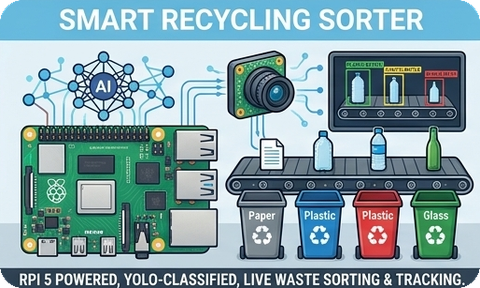
Smart Recycling SorterSmarter Recycling-Sortierer
Camera and trained classifier drive a servo flap to sort waste into the right bin, live.Kamera und trainierter Klassifikator steuern eine Servo-Klappe, um Abfall live in die richtige Tonne zu sortieren.
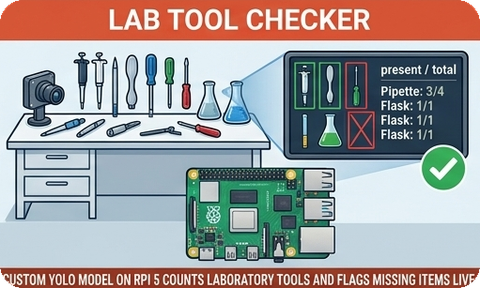
Lab Tool CheckerWerkzeug-Kontrolle
A custom-trained YOLO model counts tools on the bench and flags what's missing.Ein eigens trainiertes YOLO-Modell zählt Werkzeuge auf der Werkbank und meldet Fehlendes.
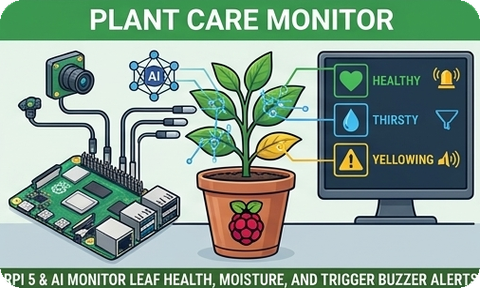
Plant Care MonitorPflanzenpflege-Monitor
Classifies healthy, thirsty or yellowing leaves and logs it with a buzzer alert.Klassifiziert gesunde, durstige oder vergilbte Blätter und protokolliert mit Summer-Alarm.
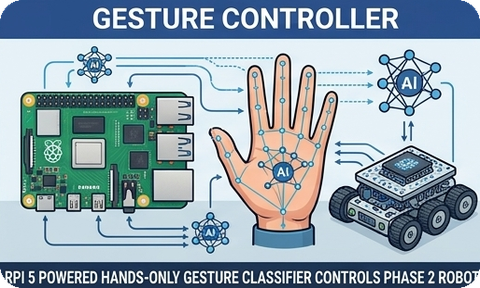
Gesture ControllerGestensteuerung
A hands-only gesture classifier drives a Phase 2 robot with no touch controls.Ein reiner Handgesten-Klassifikator steuert einen Phase-2-Roboter ganz ohne Berührung.
Conveyor CounterFörderband-Zähler
YOLO detection plus tracking counts parts crossing a line — no hand-counting.YOLO-Erkennung mit Tracking zählt Teile über eine Linie — ohne Handzählen.
Open BriefFreie Aufgabenstellung
A team-proposed school problem, approved against the class privacy rules.Ein von den Schülern vorgeschlagenes Schulproblem, geprüft gegen die Datenschutzregeln.
Week 12 — Showcase Day. A live demo and 5-minute pitch for parents, teachers and the school coordinator, a full evaluation against the original spec, and a Phase 4 preview. Woche 12 — Showcase-Tag. Eine Live-Vorführung mit 5-minütigem Pitch für Eltern, Lehrkräfte und die Schulkoordination, eine vollständige Auswertung gegen die ursprüngliche Spezifikation und ein Ausblick auf Phase 4.
Bridge to Phase 4: The Week 10 state machine and servo control lead straight into 4-DOF arm pick-and-place and AI waste sorters; the Weeks 7–9 real-time detection pipeline leads into autonomous navigation on a moving robot. Brücke zu Phase 4: Die Zustandsmaschine und Servosteuerung aus Woche 10 führen direkt zu 4-DOF-Roboterarm-Pick-and-Place und KI-Abfallsortierern; die Echtzeit-Erkennungspipeline aus den Wochen 7–9 führt zur autonomen Navigation auf einem fahrenden Roboter.